Visual-tactile fusion · ViTam
Vision fused with touch, so demonstrations carry contact forces and material response, not just pixels.
One pipeline from raw capture to licensed models, scalable and verifiable at every stage.
A multi-device capture matrix, from phones to professional kits.
On-chain rights registration and encrypted storage.
Cleaning, annotation and automated quality checks.
AXON world-model and skill-model training.
API access and industry licensing.
Vision fused with touch, so demonstrations carry contact forces and material response, not just pixels.
Universal adaptation across robot arms, humanoids and quadrupeds, so one dataset serves many bodies.
Physically consistent world models built through a calibrate–scale–simulate loop.
Automated QA and human spot checks close the quality loop. Rights are registered on-chain at capture, so every episode ships with clean provenance and a verifiable quality score.
Built for




Hardware and apps feed one data engine.
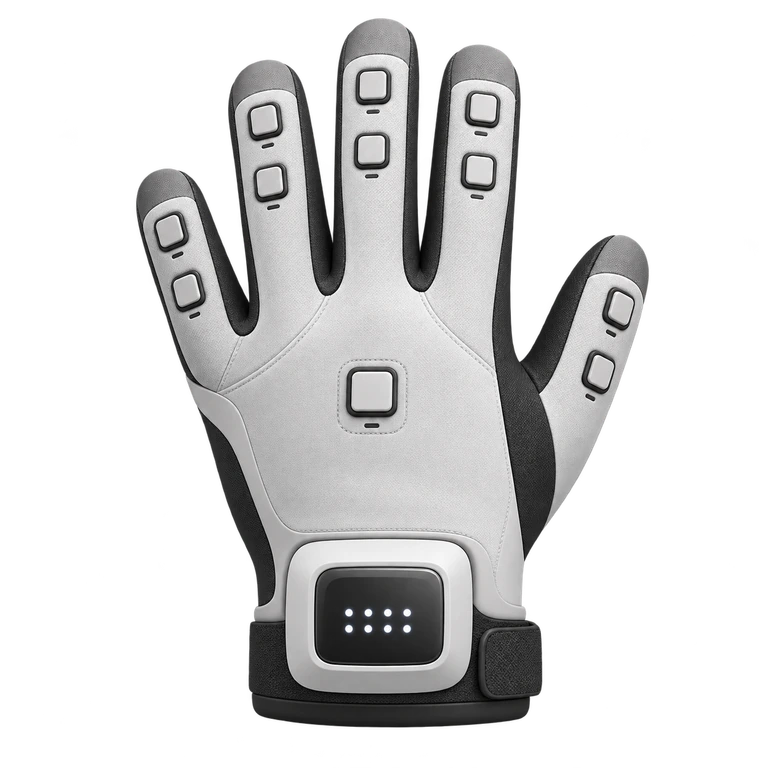
Lightweight, head-mounted multimodal capture systems for first-person real-world interaction data, alongside dedicated devices for multimodal hand-motion and tactile-pressure sensing.
Designed for: Scalable contributor networks and on-site collection teams
Data captured: RGB, IMU, and tactile glove streams
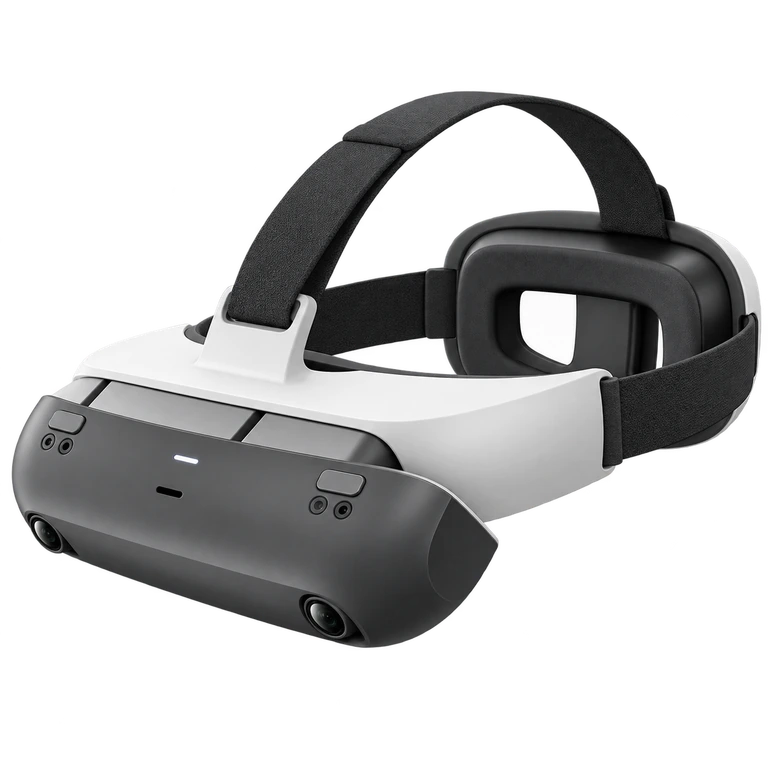
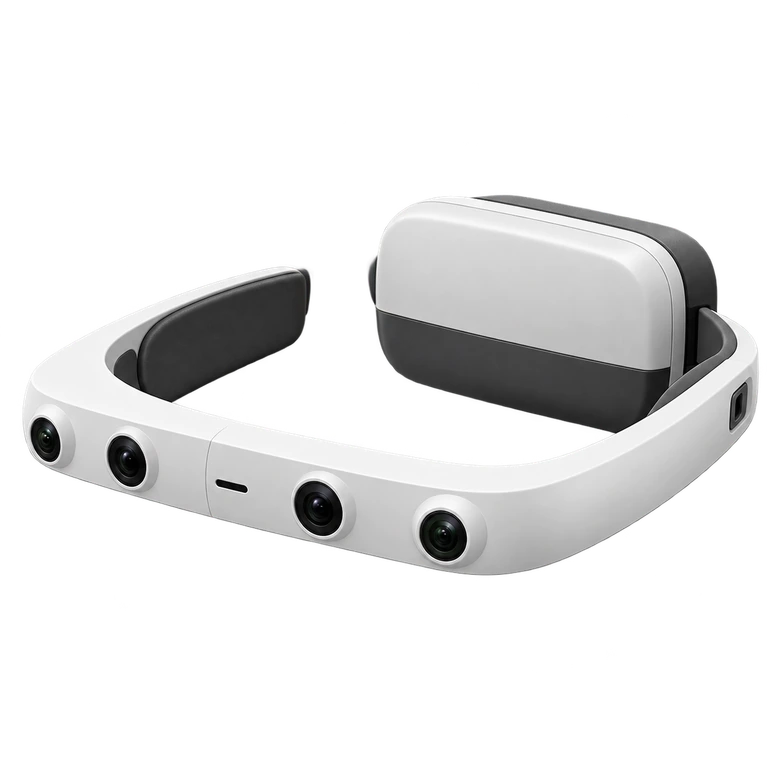
Anyone with a phone can upload scans and earn token rewards. A 3D home model can fetch $10+ on the marketplace.
Derived apps · Optimal camera placement · Daylight simulation · Renovation preview · Accessible 3D data collection
 APP STORECOMING SOON
 GOOGLE PLAYCOMING SOON
License task-specific embodied datasets or commission custom capture campaigns across our contributor network.
Assembly, kitting and tool-use data from tasks modeled on real production lines.
Shelf restocking, product picking, inventory checks and checkout workflows captured across diverse retail environments.
Medicine picking, shelf organization and order-fulfillment workflows with precise label, package and placement annotations.
Kitchen tasks, laundry and tidying in real homes, including the long tail of tasks robots struggle with.
Pick-pack-sort episodes across varied bins, parcels and shelving layouts.
Ingredient handling, meal preparation, plating and table-service workflows captured in real restaurant environments.